


Description
B&R 8MSA3M.R0-42 | Compact AC Servo Motor 4500 RPM
Dynamic Product Introduction
Navigating thermal limits on high-speed indexing heads usually comes down to finding a balance between rotor inertia and winding heat dissipation. The 8MSA3M.R0-42 hits that sweet spot for light-to-medium payload axes. Utilizing a medium rotor stack length (“M” variant) within a compact Size 3 frame (~70mm flange), this unit delivers roughly 0.90 Nm of continuous stall torque while pushing base velocity limits up to 4500 RPM without dynamic lag.
In field retrofits, replacing standard 3000 RPM motors or delicate optical encoder units with this high-speed resolver variant eliminates vibration-induced feedback faults. The integrated analog resolver (R0) provides rugged position tracking that withstands high mechanical shock and ambient oil mist far better than glass-scale optical encoders. When connected to ACOPOS drive channels, sinusoidally commutated current loops ensure smooth torque output across the entire speed envelope.
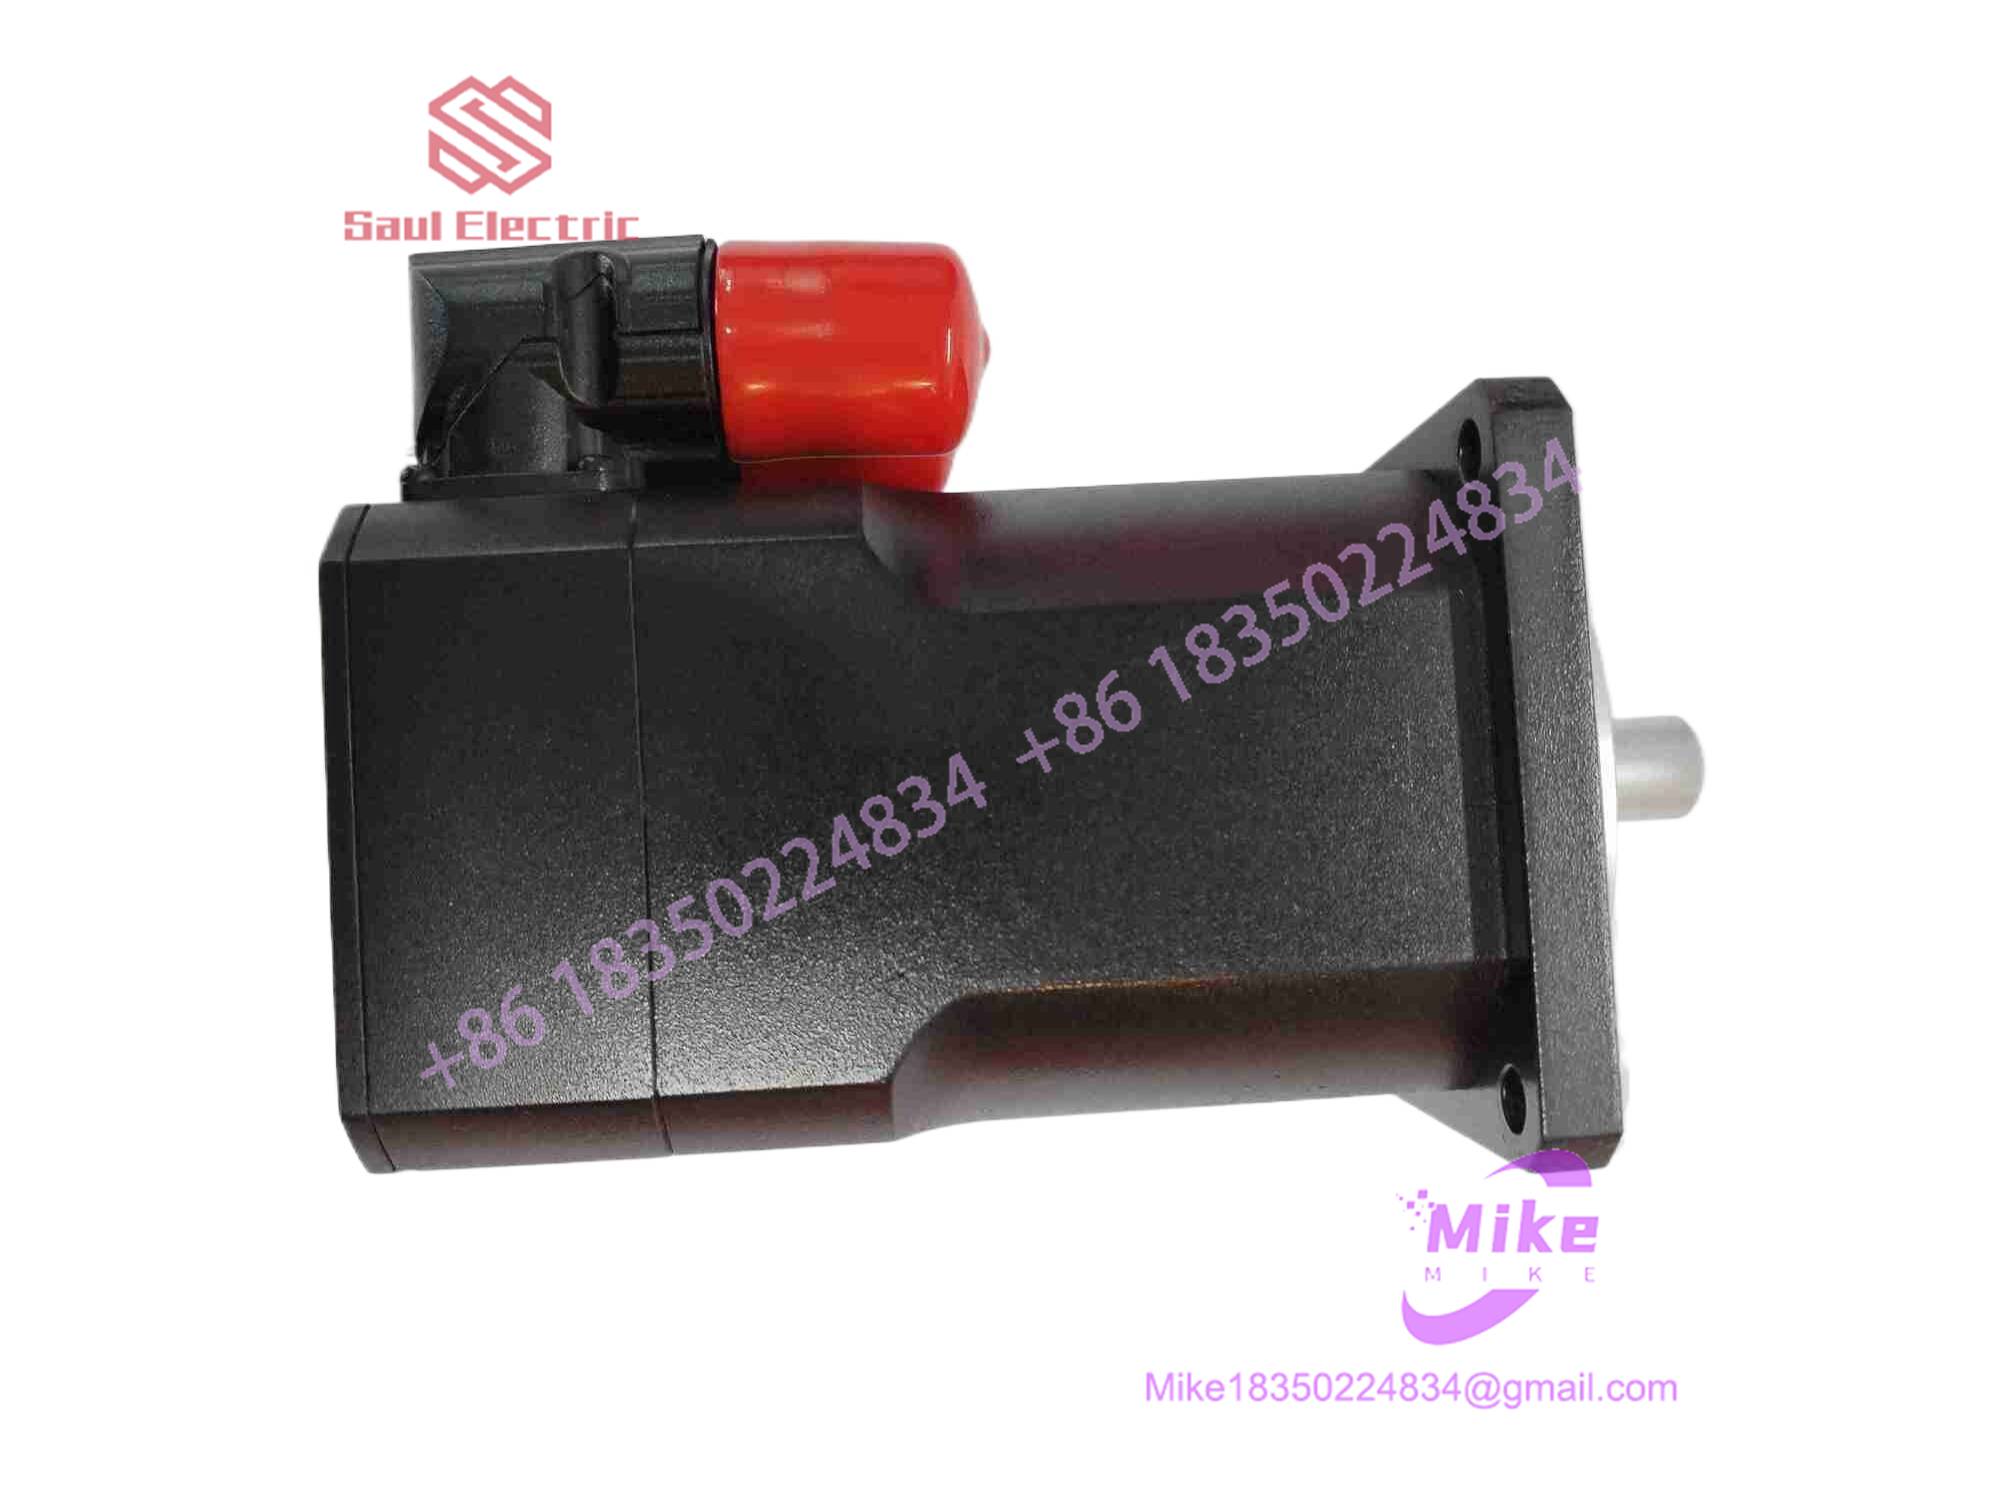
Key Technical Specifications
| Parameter | Specification | Field Note / Operational Limit |
| Rated Speed | 4500 RPM | High-velocity rating at nominal DC bus voltage |
| Stall Torque (M_0) | ~0.90 Nm | Continuous torque output (\Delta T = 100 K) |
| Peak Torque (M_{\max}) | ~3.60 Nm | Short-duration acceleration transient limit |
| Feedback System | Analog Resolver (R0 Variant) | Electromagnetic transformation feedback, high vibration resistance |
| Flange Dimensions | Size 3 (~70mm Flange) | Compact footprint for tight space constraints |
| Protection Rating | IP65 | Casing sealed against dust and splash oil (shaft seal ring fitted) |
| Connection Style | Dual SpeedTEC / Intercontec | 90-degree rotatable circular quick-lock connectors |
| Cooling Method | Natural Convection | Requires minimum 30mm surrounding air gap for natural heat dissipation |
| Thermal Protection | Embedded Thermal Sensor | Monitored directly via internal feedback wiring loop |
Global Sourcing & Live-Test SOP (Transparency Core)
Sourcing replacement surplus motion hardware demands rigorous quality checks—installing a motor with degraded resolver bobbins or bearing race pitting causes immediate positioning jitter under load. Here is our exact multi-stage quality control workflow before any unit ships:
- Inbound Mechanical Traceability:
We clamp the shaft under digital dial indicators to verify radial and axial runout stay within factory spec (<0.015mm). Serial nameplates are verified against B&R build databases to filter out counterfeit relabeling.
- ACOPOS Bench Simulation Setup:
The unit mounts to a dedicated test bench interfaced with an authentic ACOPOS drive channel connected to an Automation Studio control rack.
- Diagnostic Test Routine:
- Resolver Phase Handshake: We capture excitation carrier waves on an oscilloscope to confirm zero signal distortion and verify correct transformation ratios across 360^\circ.
- Full-Speed Dynamic Test: The unit undergoes a continuous 3-hour velocity profiling run reaching 4500 RPM, tracking real-time winding temperature stabilization and bearing acoustic noise.
- Dielectric Megger Test: A 1000V DC surge test across phase-to-phase and phase-to-ground paths guarantees zero insulation breakdown.
- Final ESD Packaging:
Shaft extensions receive rust-inhibiting grease and protective caps. The complete assembly is wrapped in static-shielding film and cradled in custom high-density foam packaging.
The Field Engineer’s Pitfall Guide
- ❗ Resolver Null-Point Offset Errors from End-Cap Tampering:
Never loosen or adjust the rear end-cap assembly on an
R0motor variant. On B&R motors, the physical alignment of the resolver stator relative to the rotor’s magnetic poles is factory-pinned. Shifting the resolver body even by a fraction of a millimeter alters the commutation angle, causing the ACOPOS drive to draw massive current spikes or throwCommutation Angle Error 9005immediately upon enabling power. - ❗ Forcing Connector Rotation Under Cable Strain:
While the SpeedTEC right-angle circular connectors swivel for flexible cable routing, attempting to turn the connector housing while the mating cable plug is locked down will twist and shear internal stator lead wires. Always unlock and remove the mating cable plug completely before adjusting the connector orientation.
- ❗ Shaft Coupling Damage from Direct Mechanical Impact:
Because Size 3 shafts are precision-ground, hammering gear couplings or timing pulleys onto the shaft extension will collapse internal ball bearing races and fracture the resolver winding bobbin positioned directly behind the rear bearing. Always draw couplings on smoothly using a threaded puller tool anchored in the shaft’s tapped center hole.
Intent-Driven FAQ
Will my ACOPOS drive automatically configure itself when I install this motor?
If your system uses standard ACOPOS motor database entries in Automation Studio, selecting the model code 8MSA3M.R0-42 automatically assigns matching current limits, resolver excitation frequencies, and velocity loop gains.
What is the primary difference between the 8MSA3M and 8MSA3L series?
The primary difference is the stack length. The “M” variant uses a medium stack length, optimized for higher velocity (4500 RPM) with ~0.90 Nm stall torque, whereas the “L” (long stack) variant delivers higher torque (~1.20 Nm) at a lower nominal speed (3000 RPM).
Can I replace an 8MSA3M.R0-42 with an optical encoder motor like an 8MSA3M.E0 series?
Not without modifying your drive configuration and cabling. Optical EnDat encoders (E0) require digital serial data communication lines and a different pinout configuration at the ACOPOS drive compared to analog resolver excitation channels. Your Automation Studio project hardware tree must match the exact feedback variant installed.
What should I check if Automation Studio throws a motor overtemperature error upon installation?
First, check the feedback cable connection. The motor’s internal thermal sensor signal routes through dedicated pins inside the resolver connector. An unseated connector or pushed-back pin creates an open circuit, which the drive interprets as an extreme thermal fault above 150^\circC.
How can I confirm if a replacement 8MSA3M motor is factory unused?
Inspect the mounting flange face, shaft keyway, and gold connector pins. Unused factory-sealed stock exhibits zero bolt compression rings or paint scraping around the flange holes, unmarred shaft surfaces, pristine gold connector pins without insertion tracking, and original protective caps intact over the shaft extension and electrical connectors.





