Description
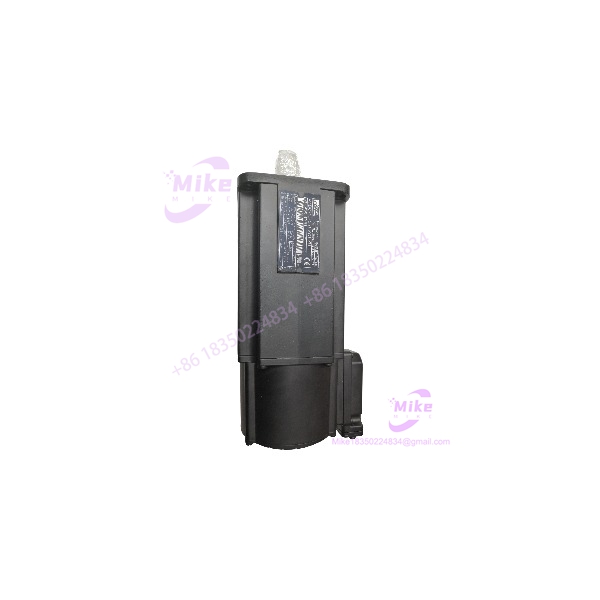
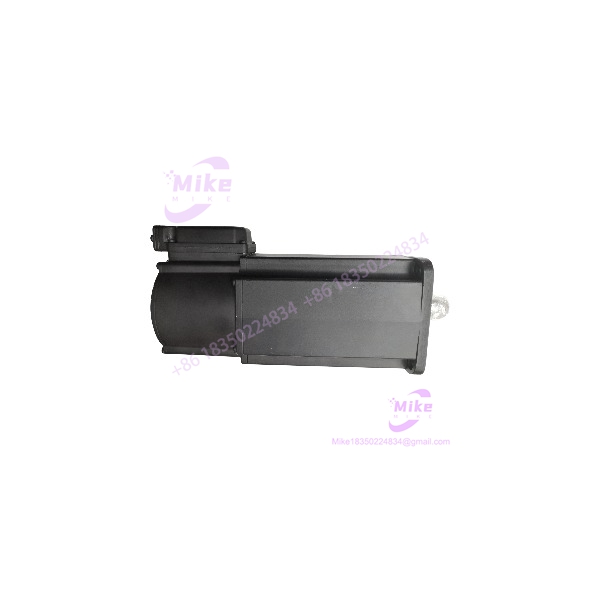
MKD071B-061-KG1-KN | 6000 RPM Servo Motor
Product Introduction
The Bosch Rexroth Indramat MKD071B-061-KG1-KN is an MKD-series permanent-magnet synchronous servo motor configured for closed-loop industrial motion control. The 071B frame uses the 061 winding and a resolver feedback system with integrated multiturn absolute position detection. The KG1 configuration combines a plain shaft with an integrated holding brake, while the KN configuration uses the standard connection-box arrangement.
This particular motor is specified around an 8.0 Nm continuous standstill torque, 5.3 Nm rated torque, and 32 Nm peak torque. The exact R911260468 documentation specifies 0.8 kW rated power, 5,000 RPM rated speed, and 6,000 RPM maximum speed. Its 115 mm flange, 95 mm centering diameter, resolver/absolute feedback, and 5 Nm brake make the complete type code important when sourcing a replacement.
MKD071B-061-KG1-KN
Key Technical Specifications
- Manufacturer: Bosch Rexroth Indramat
- Model: MKD071B-061-KG1-KN
- Material/Order Number: R911260468
- Series: MKD Synchronous Motors
- Motor Size: 071
- Motor Length: B
- Winding Code: 061
- Rated Power: 0.8 kW
- Rated Speed: 5,000 RPM
- Maximum Speed: 6,000 RPM
- Characteristic Motor Speed: 4,500 RPM in published MKD technical data
- Rated Torque: 5.3 Nm
- Continuous Standstill Torque: 8.0 Nm under natural-cooling 60 K conditions
- Continuous Standstill Current: 11.2 A under natural-cooling 60 K conditions
- Peak Torque: 32 Nm
- Peak Current: 50.4 A
- Torque Constant: Approximately 0.77 Nm/A at 20°C
- Winding Resistance: Approximately 1.45 ohms at 20°C
- Winding Inductance: Approximately 7.2 mH
- Pole Pairs: 4
- Rotor Inertia: Approximately 8.7 × 10⁻⁴ kg·m²
- Feedback: Resolver with integrated multiturn absolute encoder
- Position Detection: Absolute, greater than 4,096 revolutions
- Shaft: Plain shaft with shaft sealing ring
- Holding Brake: Yes
- Holding Brake Torque: 5 Nm
- Brake Supply: 24 VDC
- Connection: Connection box / terminal box
- Connection Direction: Side B
- Flange Size: 115 mm
- Centering Diameter: 95 mm
- Protection Rating: IP65
- Insulation Class: F
- Ambient Operating Range: Approximately 0°C to +40°C
- Motor Mass: Approximately 8.8 kg
Application Scenarios & Pain Points
1. Legacy Indramat Servo-Axis Replacement
The MKD071B-061-KG1-KN is suited to maintenance replacement where the installed machine uses the same 061-winding MKD071B configuration.
Engineering pain point: A replacement selected only by frame size can have the wrong winding, feedback, shaft, or brake configuration.
2. Machine-Tool and Positioning Axes
The motor combines a 5.3 Nm rated torque point with resolver-based absolute position feedback for closed-loop servo applications.
Engineering pain point: The replacement drive must be configured for the correct motor feedback and winding data. Do not assume another MKD071B motor can use the same parameter set.
3. Packaging and Automated Production Equipment
The 071 frame provides a larger motor package for automated axes where a compact permanent-magnet servo motor is required.
Engineering pain point: The 115 mm flange and 95 mm centering pilot must match the machine-side mounting geometry, while the plain shaft must match the coupling.
4. Vertical and Load-Holding Axes
The integrated 5 Nm holding brake provides mechanical holding when the motor is de-energized.
Engineering pain point: Brake torque must be compared with the actual static load torque. A holding brake should not be treated as the machine’s dynamic stopping system.
5. Hydraulic Pump and Rotary Drive Applications
The exact -061-KG1-KN has also been documented in an engineering application driving a hydraulic pump, demonstrating its use beyond conventional linear positioning axes.
Pain point: Pump inertia, coupling alignment, acceleration torque, and continuous thermal loading must be evaluated together rather than selecting the motor from torque alone.
QA & Live Testing SOP
1. Identity Verification
- Photograph the complete motor nameplate.
- Confirm MKD071B-061-KG1-KN.
- Verify material/order number R911260468 where marked.
- Confirm winding code 061.
- Confirm the KG1 feedback/shaft/brake configuration.
- Record the serial number and manufacturing information.
2. Mechanical Inspection
- Verify the 115 mm flange and 95 mm centering diameter.
- Inspect the plain shaft for scoring, corrosion, impact marks, and coupling wear.
- Check the shaft sealing ring.
- Rotate the shaft manually and listen for bearing noise.
- Check radial and axial play.
- Inspect the connection box for cracked insulation, loose terminals, and contamination.
3. Holding-Brake Test
- Apply a controlled 24 VDC brake supply.
- Verify positive brake release.
- Remove brake power and verify mechanical engagement.
- Check brake current against the applicable motor documentation.
- Confirm the brake does not drag after release.
- Do not use the brake as a dynamic stopping device during the incoming inspection.
4. Motor Winding Test
- Measure resistance between all motor phases.
- Compare phase-to-phase measurements for balance.
- Perform insulation-resistance testing using an appropriate motor test procedure.
- Check each winding against the motor frame.
- Record measurements and ambient temperature.
- Keep feedback electronics isolated from inappropriate high-voltage test equipment.
5. Feedback Test
- Inspect resolver wiring and terminals.
- Check the feedback connector/interface for damage.
- Connect the motor to a compatible Rexroth/Indramat drive test system.
- Confirm resolver feedback is detected correctly.
- Verify position feedback at low speed.
- Confirm correct rotation direction and absolute/multiturn position behavior.
6. Controlled Rotation Test
- Begin at low speed with current limits active.
- Confirm correct rotation direction.
- Monitor phase current and following error.
- Check vibration and bearing noise.
- Increase speed progressively within the verified test-rig limits.
- Do not use 6,000 RPM as a routine incoming-test speed.
7. Documentation and Packaging
- Record nameplate photographs and serial number.
- Record winding, insulation, brake, feedback, and rotation-test results.
- Protect the plain shaft against impact.
- Protect the connection box and feedback circuitry from ESD and mechanical shock.
- Use rigid packaging that prevents shaft loading during transportation.
Field Engineer’s Pitfall Guide
❗ Do not confuse the 061 winding with the 035 winding.
Both are used on motors, but their electrical characteristics differ. The complete designation should be matched before procurement.
❗ KG1 means a plain shaft plus holding brake.
The MKD type-code documentation identifies K as multiturn resolver feedback, G as a smooth/plain shaft, 1 as holding brake fitted, and K as the terminal-box connection.
❗ Do not treat all published speed figures as equivalent.
The exact R911260468 source lists 5,000 RPM rated speed and 6,000 RPM maximum speed, while other technical references identify 4,500 RPM as characteristic motor speed. These values describe different documentation points and should not be substituted for one another.
❗ Cooling changes the torque/current envelope.
Published data gives approximately 8.0 Nm continuous standstill torque at natural cooling/60 K, while surface cooling can permit a higher continuous standstill value. Confirm the cooling method before using the higher rating.
❗ The 5 Nm brake is not the motor’s torque rating.
The motor has 8.0 Nm continuous standstill torque and 32 Nm peak torque, while the integrated brake is rated at 5 Nm. They serve different functions.
❗ Verify the drive and feedback configuration together.
The KG configuration uses resolver feedback with integrated multiturn absolute position detection. A visually similar motor with another feedback code should not be assumed compatible.
Intent-Driven FAQ
What is ch Rexroth ?
It is a Bosch Rexroth Indramat MKD permanent-magnet synchronous AC servo motor with a 071B frame, 061 winding, resolver/multiturn absolute feedback, plain shaft, and integrated 5 Nm holding brake.
What is the order number?
The material/order number associated with is R911260468.
What is the continuous standstill torque?
The documented natural-cooling value is 8.0 Nm at standstill under the applicable 60 K thermal condition.
What is the rated power?
The exact R911260468 documentation lists 0.8 kW rated power.
What is the rated speed?
The exact-model documentation lists 5,000 RPM rated speed and 6,000 RPM maximum speed. Other MKD technical references list 4,500 RPM as the characteristic motor speed, so the terms should not be treated as interchangeable.
Does the have a holding brake?
Yes. The KG1 configuration includes a 5 Nm holding brake with 24 VDC actuation.
Does it have a keyed shaft?
No. The KG1 configuration uses a plain/smooth shaft with a shaft sealing ring.
What feedback does it use?
It uses resolver feedback with an integrated multiturn absolute encoder, with absolute position detection exceeding 4,096 revolutions.
What are the mounting dimensions?
The documented motor uses a 115 mm flange and 95 mm centering diameter.
Is this motor interchangeable with another motor?
Not automatically. The winding code, feedback, shaft, brake, connection configuration, and drive parameters must all be checked. The complete type code should be matched before approving a replacement.
What should be te a surplus ?
At minimum, verify the nameplate and identity, shaft and bearing condition, phase resistance balance, insulation, brake operation, resolver feedback, low-speed rotation, current behavior, and connection-box condition.