Description
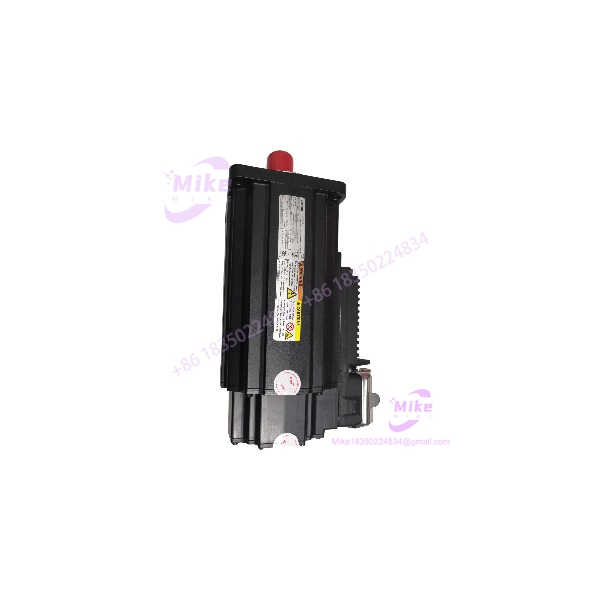
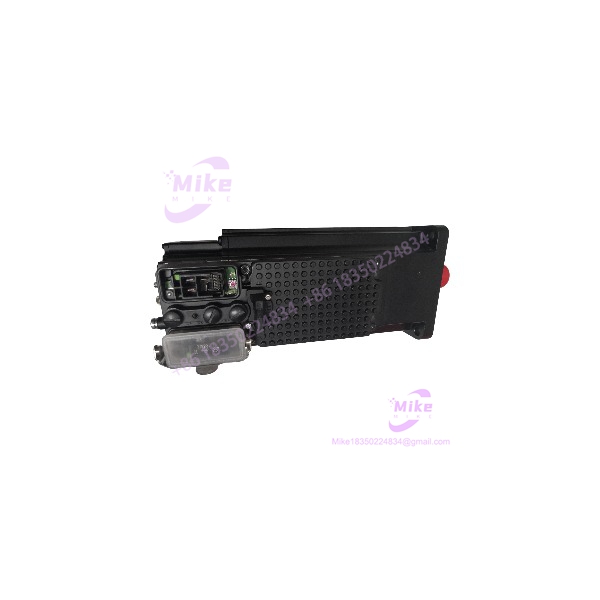
Rexroth KSM01.2B-061C-61N-M1-HG2-SE-NN-D7-NN-FW R911320611
Product Introduction
The Bosch Rexroth KSM01.2B-061C-61N-M1-HG2-SE-NN-D7-NN-FW (R911320611) combines the servomotor and drive electronics in a distributed motion-control assembly. This reduces the need for a separate cabinet-mounted drive at the motor location, but it also makes exact configuration matching essential when replacing a failed unit.
This variant is listed with a DC 750 V supply, natural-convection cooling, SERCOS 2 (RS422) communication, and a multi-turn Hiperface encoder. The integrated 24 VDC electrically released holding brake and IP65 protection rating are also identified in supplier specifications. Maximum motor speed is listed at 6,000 rpm; a distributor lists 18 Nm maximum torque, which should be verified against the applicable Rexroth motor data and operating conditions.
For legacy machine support, R911320611 should be sourced as a complete, configuration-matched motor-integrated drive—not as a generic servo motor. The complete type code, firmware requirements, feedback configuration, and communication architecture must be checked before installation.
KSM01.2B-061C-61N-M1-HG2-SE-NN-D7-NN-FW
Key Technical Specifications
- Manufacturer: Bosch Rexroth
- Model: KSM01.2B-061C-61N-M1-HG2-SE-NN-D7-NN-FW
- Material Number: R911320611
- Product Series: IndraDrive Mi KSM
- Design: Compact B05
- Design Version: 2
- Motor Size: 061
- Motor Length: C
- Winding Code: 61
- Supply Voltage: DC 750 V
- Maximum Motor Speed: 6,000 rpm
- Maximum Torque: 18 Nm, distributor-listed; verify against the motor data
- Communication Protocol: SERCOS 2 (RS422)
- Communication Architecture: KCU electronic control system
- Encoder Interface: Hiperface
- Encoder Technology: Optical
- Encoder Type: Multi-turn absolute
- Encoder Resolution: 128 signal periods
- Holding Brake: Electrically released
- Holding Brake Voltage: 24 VDC
- Cooling Method: Natural convection
- Connection: Hybrid connector
- Protection Rating: IP65 according to IEC 60529
- Motion Logic: Integrated motion logic supporting IEC 61131-3
- Firmware: Ordered separately, according to supplier documentation
- Safety Technology: No safety technology identified for this exact configuration
The full ordering code is important. For example, related KSM configurations may use different encoder turn types or motor options. Do not substitute a nearby type-code variant without checking the machine’s original configuration and Rexroth documentation.
Global Sourcing & Live-Test SOP
A used or surplus R911320611 should be evaluated as an integrated motor and drive assembly. A basic electrical check cannot establish encoder, brake, or communication performance.
5.1 Inbound Verification
- Photograph the complete nameplate and all identification labels.
- Confirm the full type code and material number R911320611.
- Record serial number, hardware revision, and manufacturing data.
- Inspect the motor housing, mounting surfaces, shaft, and connector interfaces.
- Check the hybrid connector for bent contacts, corrosion, contamination, or mechanical damage.
- Inspect for signs of moisture ingress, overheating, impact, or unauthorized repair.
- Confirm whether firmware, cables, and other accessories are included or excluded.
- Request a written test report and condition classification from the seller.
5.2 Controlled Power-Up
- Use a qualified test setup and the applicable Rexroth commissioning procedure.
- Verify the DC 750 V supply architecture and required auxiliary/control supplies before energizing.
- Confirm correct grounding, protective bonding, and connector mating.
- Record startup behavior, diagnostic status, and fault history.
- Do not bypass safety interlocks or improvise high-voltage test connections.
- Follow the manufacturer’s isolation and DC-link discharge procedure before handling the unit.
5.3 Functional Diagnostics
- Confirm the controller and communication architecture are compatible with the installed unit.
- Verify the required firmware and commissioning data are available.
- Check encoder feedback and absolute-position behavior using an approved test arrangement.
- Test holding-brake operation through the specified interface and procedure.
- Verify motor rotation and feedback direction under controlled conditions.
- Record communication faults, encoder alarms, and brake-related diagnostics.
- Do not declare the assembly production-ready based only on a successful power-up.
5.4 Extended Heat Run
Where an approved test setup is available, conduct an extended functional run under representative operating conditions.
Monitor and record:
- Drive status and fault history
- Motor speed and load behavior
- Encoder feedback stability
- Holding-brake operation
- Housing temperature
- Communication stability
- Unexpected trips or resets
Record test duration, firmware/configuration details, test conditions, and observed faults. Do not claim a 24-hour heat run unless it was completed and documented.
5.5 Final Preparation and Shipment
- Preserve the original nameplate and identification labels.
- Record the tested firmware and configuration, where available.
- Photograph the shaft, connectors, housing, and nameplate before packing.
- Protect connectors and exposed electronics with ESD-safe packaging.
- Secure the shaft and motor assembly against impact during transit.
- Clearly identify included accessories and any firmware or configuration exclusions.
- Distinguish tested, repaired, refurbished, unused-surplus, and untested condition accurately.
Field Engineer’s Pitfall Guide
❗ Do not treat the 750 VDC supply designation as a generic wiring instruction
The listed DC 750 V supply relates to the IndraDrive Mi system architecture. Confirm the exact supply arrangement, connection requirements, and safe isolation procedure from the applicable Rexroth documentation before installation.
❗ Firmware and commissioning data are not automatically included
Supplier documentation lists firmware as separately ordered. A physically compatible may still require the correct firmware, controller configuration, and commissioning data to operate as intended. Confirm these items before purchase.
❗ Verify the encoder and brake configuration—not just the motor frame
This type code identifies a multi-turn Hiperface encoder and a 24 VDC electrically released holding brake. Related KSM variants can differ in encoder or option selections. Match the full ordering code and confirm encoder and brake compatibility before commissioning.
Intent-Driven FAQ
What is the Bosch Rexroth ?
is the material number for the KSM01.2B-061C-61N-M1-HG2-SE-NN-D7-NN-FW IndraDrive Mi motor-integrated servo drive.
Is a servo motor or a servo drive?
It is a motor-integrated servo drive. The KSM assembly combines the servomotor and drive electronics rather than functioning as a conventional standalone motor alone.
What is the maximum speed of this KSM01.2B variant?
Supplier specifications list a maximum motor speed of 6,000 rpm. Confirm permissible operating speed and load conditions using the applicable Rexroth motor data.
What encoder does use?
This configuration is listed with an optical Hiperface multi-turn absolute encoder with 128 signal periods. Verify the complete type code and encoder configuration on the physical unit before replacement.
Does this model include a holding brake?
Yes. The exact configuration is listed with an electrically released 24 VDC holding brake. Confirm brake condition and operation during testing.
Is firmware included with ?
Do not assume so. Supplier documentation identifies firmware as ordered separately. Ask the seller whether the required firmware and commissioning data are included and compatible with the target system.
Can I replace another KSM01.2B unit with ?
Not based on the family designation alone. Compare the full type code, material number, motor/winding configuration, encoder, brake, communication protocol, and firmware requirements against the installed assembly.
Bottom Line for Buyers
The is a configuration-specific IndraDrive Mi motor-integrated servo drive, with a listed 6,000 rpm maximum speed, DC 750 V supply, SERCOS 2 communication, multi-turn Hiperface feedback, and a 24 VDC holding brake.
For procurement, require a clear nameplate photograph and confirmation of the complete type code. Verify firmware availability, encoder/brake configuration, and controller compatibility before approving the assembly as a production replacement.