


Description
Kollmorgen AKD-N00307-DSEC-E000 | Quantified Spec 3A IP67 EtherCAT Unit
Dynamic Product Introduction
Machine builders looking to slash cabinet footprints often lean on decentralized motion topologies. The Kollmorgen AKD-N00307-DSEC-E000 mounts directly onto the machine frame right next to the motor, drastically reducing heavy multi-conductor cabling runs through traditional cable tracks. Trading standard enclosure-bound amplifiers for this rugged, IP67-rated unit demands strict adherence to hybrid power distribution rules, making verified hardware acquisition critical for system uptime.
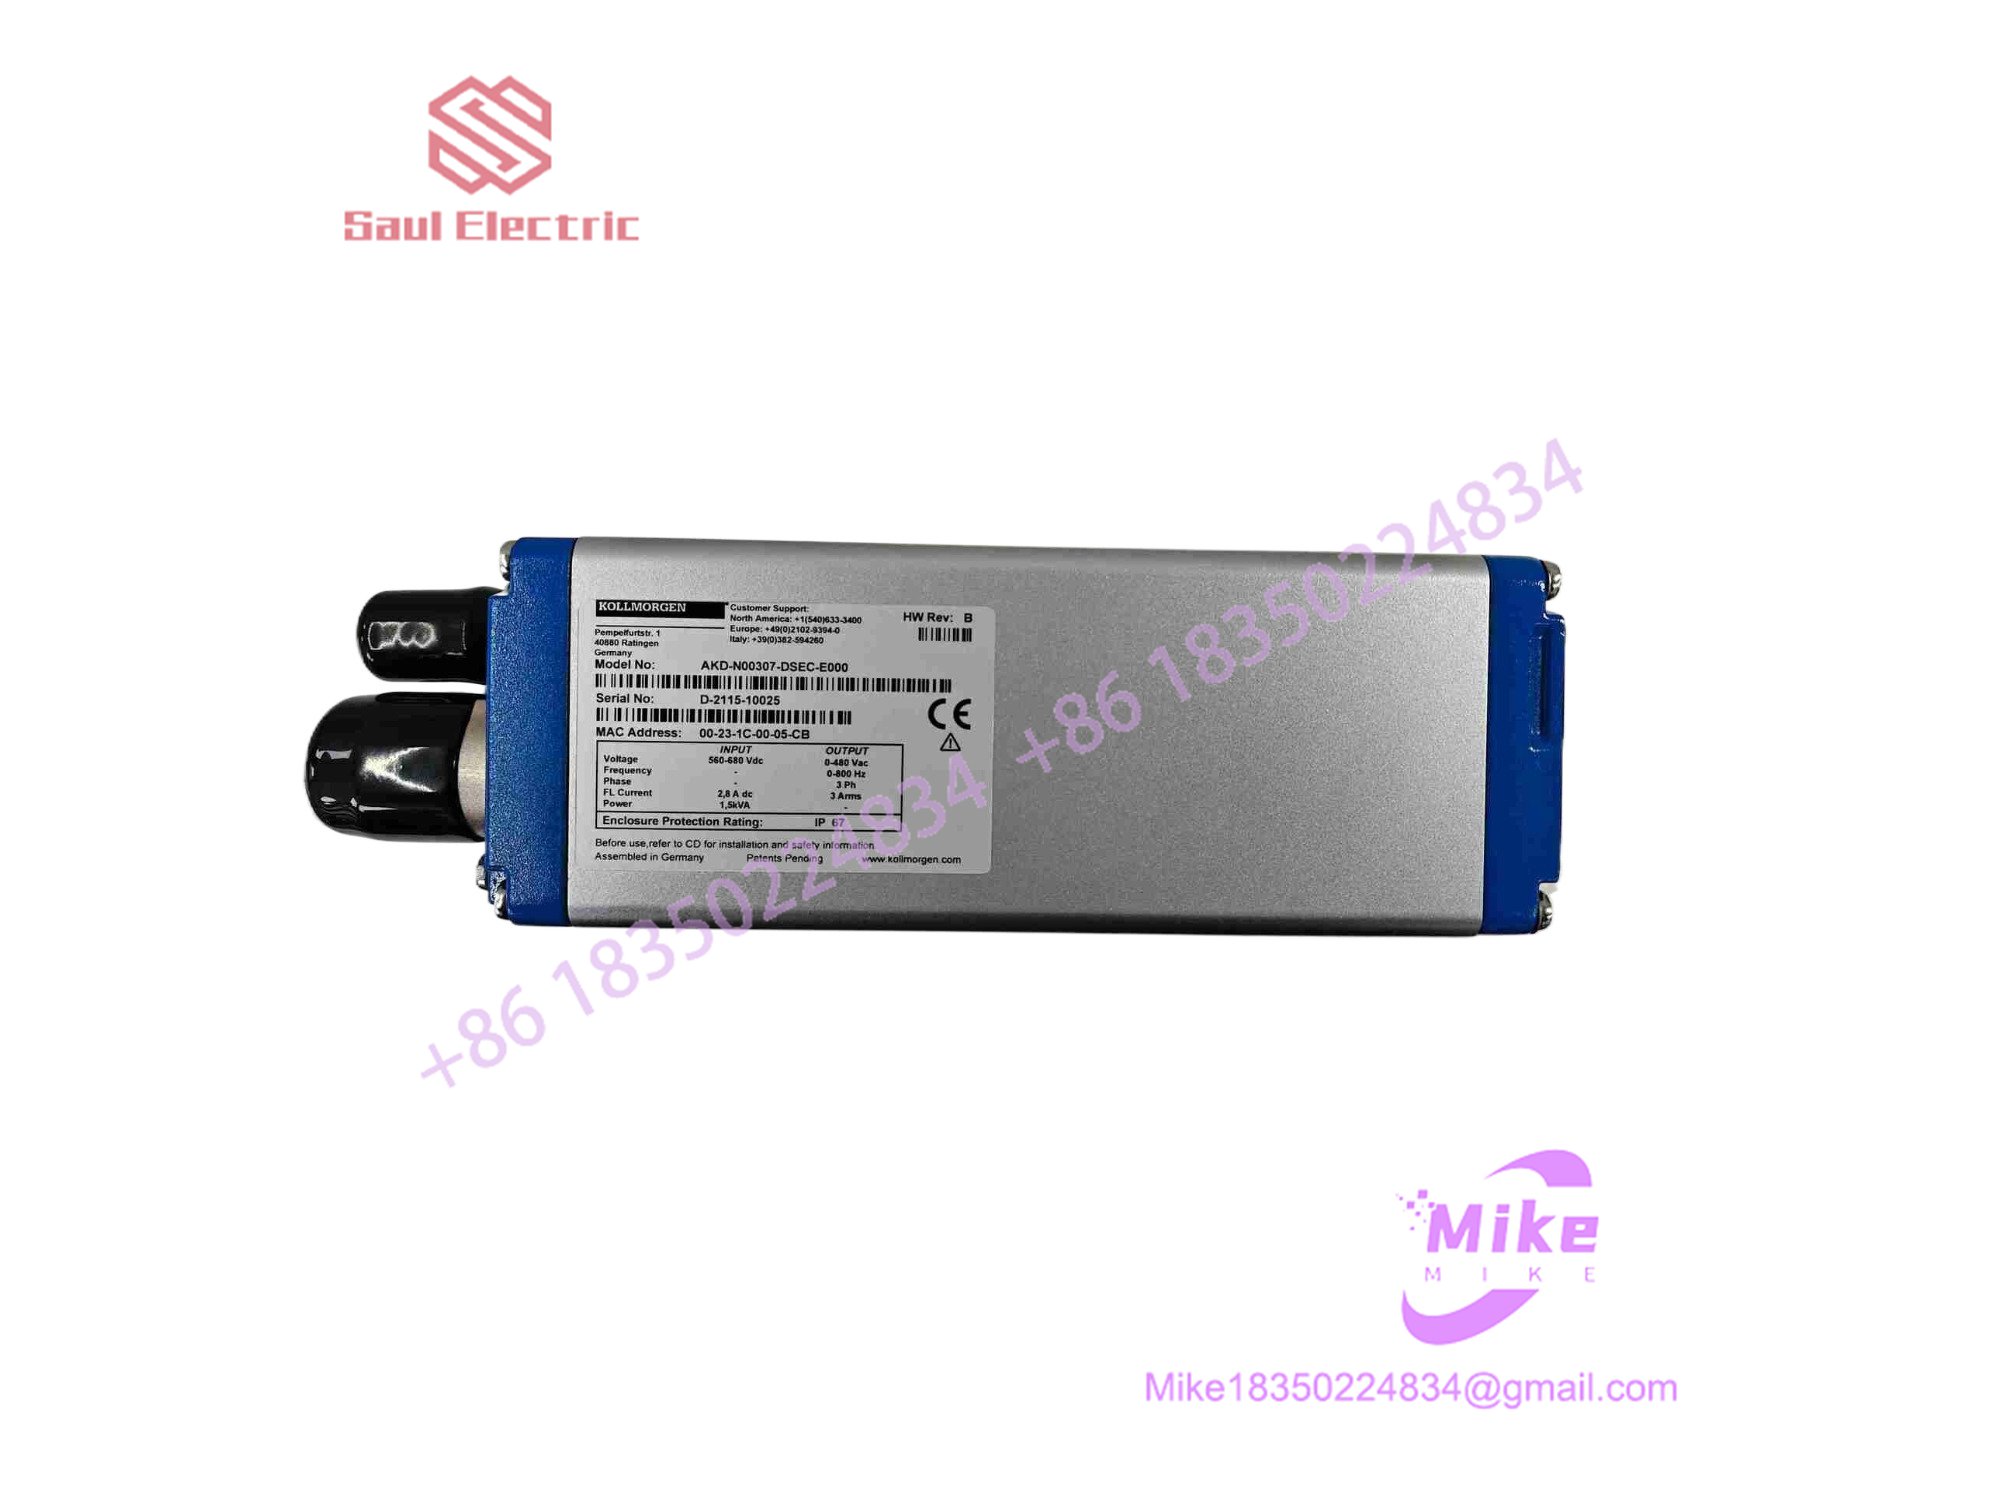
AKD-N00307-DSEC-E000
Key Technical Specifications
| Technical Parameter | Specification Value |
| Input Supply Voltage | 560 VDC to 680 VDC (via AKD-C centralized supply) |
| Continuous Output Current | 3.0 A |
| Peak Output Current | 9.0 A |
| Continuous Power Rating | 2.6 kW |
| Communication Interface | EtherCAT (Real-time motion bus) |
| Enclosure Protection | IP67 (Washdown and dust resistant) |
| Feedback Support | Multi-feedback (SFD, BiSS-C, EnDat 2.1/2.2, Hiperface DSL) |
| Safety Feature | Local Safe Torque Off (STO, SIL 2 / PLd variant) |
| Physical Dimensions | 75 mm x 130 mm x 201 mm |
| Vibration Rating | 3M5 mechanical stress tolerance |
Global Sourcing & Live-Test SOP (Transparency Core)
Procuring secondary or surplus decentralized drives requires verifying high-frequency switching health and internal logic isolation. Every AKD-N unit undergoes an uncompromising evaluation workflow:
- Inbound Verification: Serial number lineage tracking, anti-counterfeit holographic label authentication, and M23 connector pin check to confirm zero galvanic corrosion or bent pins.
- Live Simulation: Plugged directly into an authentic AKD-C master power supply rack paired with a matching test servomotor.
- Diagnostics: Full-load thermal cycling run for 24 hours, verification of the EtherCAT real-time cyclic synchronous position (CSP) loop, and encoder feedback validation across multi-turn absolute formats.
- Final Prep: Complete firmware flash backup record check, port dust-cap installation, and static-dissipative vacuum sealing.
The Field Engineer’s Pitfall Guide
- ❗ Hybrid Cable Length Violations: Exceeding the maximum total combined length permitted between the central AKD-C supply and string-connected AKD-N drives will cause severe voltage drop and bus synchronization faults.
- ❗ Ignoring Grounding Continuity: Because the drive chassis relies on machine frame grounding for high-frequency noise suppression, failing to secure the braided shield clamp directly to the backplate will result in intermittent EtherCAT packet loss.
- ❗ Brake Power Budget Overlooks: Assuming the 3A AKD-N00307 variant can drive heavy holding brakes without checking the 1A brake current limit will trip the internal protection circuitry of the stand-by supply.
Intent-Driven FAQ
- Can I hot-swap an AKD-N00307-DSEC-E000 drive while the central DC bus is energized?
Never disconnect the hybrid cable while the system is powered. Always lock out the upstream AKD-C supply and verify that the 55V standby voltage and high-voltage bus capacitors have fully discharged to avoid arc-flash damage to the SpeedTec connectors.
- Does this drive require a local parameter backup if replaced?
The drive pulls its operational parameters from the master controller or workstation project file via EtherCAT upon boot, though matching firmware major revisions is critical to prevent handshake rejections.
- What indicates a failing internal feedback circuit on this model?
Random drive trips with phase errors or encoder communication warnings during high-axis acceleration cycles usually point to noise induction or a degraded hybrid cable internal data pair.
- Is the STO function on this specific suffix rated for safety integration?
Yes, the -DS designation indicates integrated local Safe Torque Off capability matching SIL 2 / PLd safety requirements, provided external safety wiring is looped correctly.
- What warranty conditions apply to surplus units?
Verified units include an industry-standard replacement guarantee covering internal semiconductor and functional integrity under normal operating loads.





