


Description
NSK ESA-1010A35-21 | Megatorque Servo Drive
Product Introduction
This is not simply a motor amplifier that accepts a speed command and produces current. The NSK ESA-1010A35-21 belongs to the Megatorque servo-drive architecture, where the drive closes the control loop around a direct-drive torque motor and its position feedback. That makes it relevant to machines requiring controlled rotary positioning without the mechanical reduction stages normally associated with conventional servo arrangements.
The ESA-1010A35 family provides the control functions expected in precision motion equipment — position, velocity, and torque control, resolver feedback processing, programmable motion functions, and diagnostic/alarm handling. Service documentation also identifies RS-232C communication, pulse-train command capability, dedicated motor and resolver connections, and hardware emergency-stop and over-travel inputs.
For lifecycle maintenance, the ESA-1010A35-21 is particularly relevant when the original Megatorque architecture must remain intact. Replacing the drive with a generic servo amplifier can require motor-characteristic changes, feedback conversion, parameter migration, and machine-level commissioning.
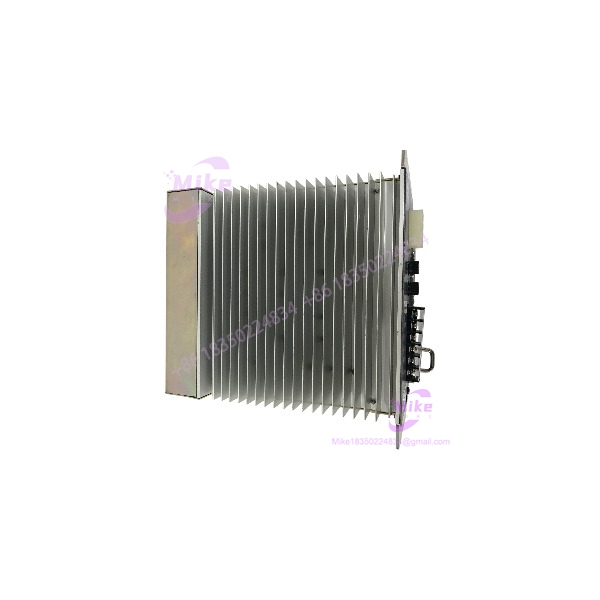
ESA-1010A35-21
Key Technical Specifications
- Manufacturer: NSK
- Model: ESA-1010A35-21
- Model Format: ESA1010A3521
- Product Type: Megatorque servo drive / control drive
- Drive Family: ESA-1010A35
- Primary Application: Direct-drive torque motor control
- Control Modes: Position, velocity, and torque control
- Feedback: Resolver position feedback
- Command Interface: Pulse-train input
- Analog Command: Velocity / torque command interface
- Serial Interface: RS-232C
- Main AC Input: Approximately 200–220 VAC for the documented drive configuration
- Control Power: Documentation identifies a separate control-power input arrangement
- Motor Connection: Dedicated motor-power connection
- Resolver Connection: Dedicated resolver interface
- Digital I/O: Servo ON, emergency stop, home, in-position, alarm, brake, and over-travel functions are documented
- Protection Functions: Overcurrent, overheat, resolver fault, position error, CPU error, and AC-line fault monitoring
- Indexer: Service documentation identifies a programmable 64-channel indexer
- Cooling: Cabinet installation with appropriate heat dissipation
- Installation: Electrical cabinet / panel-mounted servo-drive application
The exact electrical ratings and motor pairing should be verified against the drive’s nameplate and original NSK documentation. Secondary technical records agree on the general architecture but should not replace the machine-specific commissioning data.
Application Scenarios & Pain Points
Direct-drive rotary positioning
Megatorque systems are useful where the machine needs high torque and accurate rotary positioning without relying on a conventional gearbox or belt reduction. The servo drive manages the motor’s position and torque response directly through the feedback loop.
Semiconductor and precision automation
Technical descriptions of the ESA-1010A35 family associate this type of direct-drive servo architecture with semiconductor equipment, rotary indexing mechanisms, and precision positioning machinery.
Rotary indexing systems
A programmable indexer can simplify repetitive positioning sequences. Instead of requiring every movement to be generated by an external controller, the drive itself can execute stored motion programs where the machine architecture permits it.
Legacy Megatorque replacement
When an ESA-series drive fails, replacing only the amplifier can be considerably less disruptive than converting the machine to a modern third-party servo platform. The existing motor, resolver wiring, mechanical coupling, and control strategy can potentially remain intact.
Intermittent servo alarms
Resolver faults, over-current events, position errors, and over-temperature alarms can originate in several parts of the motion chain. A replacement drive should therefore be validated against the motor, feedback cable, command source, and machine parameters rather than installed as a blind component swap.
QA & Live Testing SOP
We treat the ESA-1010A35-21 as a complete servo-drive assembly, not merely an electronic spare.
Step 1 — Identity verification
We record the full model number, hardware revision, serial number, nameplate ratings, connector arrangement, and any motor-specific identification.
Step 2 — Visual inspection
The enclosure, terminal blocks, connectors, cooling surfaces, PCB areas, and mounting points are checked for corrosion, contamination, cracked components, damaged terminals, and evidence of overheating.
Step 3 — Power-stage screening
Before energization, the input and motor-power sections are inspected for obvious short circuits or damaged semiconductor devices. Stored DC-bus energy is treated as a serious electrical hazard.
Step 4 — Resolver circuit check
The resolver connector and associated wiring are inspected before connecting the drive to a motor. An open or shorted resolver circuit can trigger feedback faults and should not be mistaken for a defective drive.
Step 5 — Controlled power test
Where the appropriate test equipment is available, the drive is powered under controlled conditions and monitored for abnormal current draw, alarm status, cooling behavior, and internal diagnostics.
Step 6 — Motor feedback test
A compatible Megatorque motor is connected and the resolver feedback is verified. Position response, servo enable, commanded movement, and alarm behavior are checked within the permitted test environment.
Step 7 — Final QC
The drive is protected against ESD, moisture, and mechanical shock. Configuration information is recorded so that the replacement can be compared directly with the customer’s existing unit.
Field Engineer’s Pitfall Guide
❗ Do not substitute ESA-1010A35-21 based only on physical dimensions. The servo drive and Megatorque motor form a matched control system. Motor parameters, resolver characteristics, command scaling, and drive configuration all matter.
❗ Do not power the drive before checking the motor and resolver wiring. Service documentation identifies dedicated motor and resolver connections, while resolver faults are specifically monitored by the drive. A wiring error can produce a fault that looks like a defective amplifier.
❗ Respect the DC-bus discharge period. Service documentation specifies waiting at least five minutes after power removal before opening the drive enclosure. This is not optional maintenance etiquette — stored capacitor energy presents a genuine shock hazard.
❗ Do not ignore the emergency-stop circuit. The ESA architecture uses a dedicated emergency-stop input, and the safety circuit should be verified before commissioning motor movement.
Intent-Driven FAQ
A: It is an ESA-series Megatorque servo drive/control drive intended to operate compatible direct-drive torque motors in closed-loop motion applications.
Is a conventional VFD?
A: No. It is a servo-drive unit designed around precision motion control and resolver feedback, rather than a general-purpose variable-frequency motor drive.
Q: Whes control?
A: It is intended for compatible NSK Megatorque direct-drive motors. The exact motor pairing must be confirmed from the original machine documentation and drive nameplate.
Q: What es use?
A: The family uses resolver-based position feedback, with a dedicated resolver connection.
es have RS-232C?
A: Yes. Technical service documentation identifies an RS-232C interface used for parameter access, monitoring, and communication with the applicable service terminal.
Q: What command sihe accept?
A: The documented architecture includes pulse-train commands as well as analog velocity/torque command interfaces. The exact usable command mode depends on the machine configuration and parameterization.
Is still useful for legacy equipment?
A: Yes. Its primary value is maintaining existing Megatorque installations where the original drive, motor, resolver feedback, and machine controller are still in service. Current industrial repair/supply records continue to list the model as a serviceable legacy automation component.
he 10A35-21.1?
A: Do not assume that. Both designations appear in industrial service records, but the exact hardware revision and configuration should be matched to the unit being replaced.





