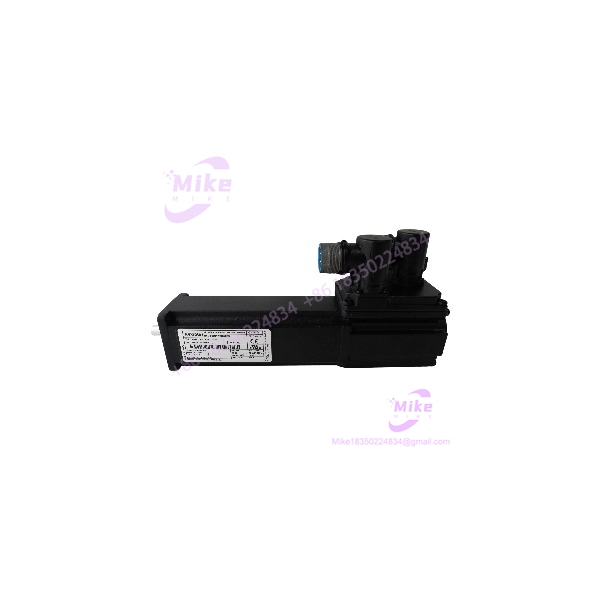
Description
Rexroth MKD025B-144-KG1-UN | Multiturn Encoder Motor
Product Introduction
The Bosch Rexroth Indramat MKD025B-144-KG1-UN is a compact MKD-series digital AC synchronous servo motor intended for closed-loop machine motion. The 025 frame and B-length configuration provide a small mechanical package while the 144 winding and KG1 feedback/brake configuration define the motor’s specific electrical and motion-control interface. The motor uses resolver feedback with an integrated multiturn absolute encoder capable of absolute position detection beyond 4,096 revolutions.
With 0.9 Nm continuous standstill torque and a documented 6,000 RPM maximum speed, this motor fits applications requiring compact rotary actuation and controlled positioning. The exact configuration includes a 1 Nm holding brake, plain shaft with shaft seal, 54 mm flange, 40 mm centering diameter, and natural convection cooling.
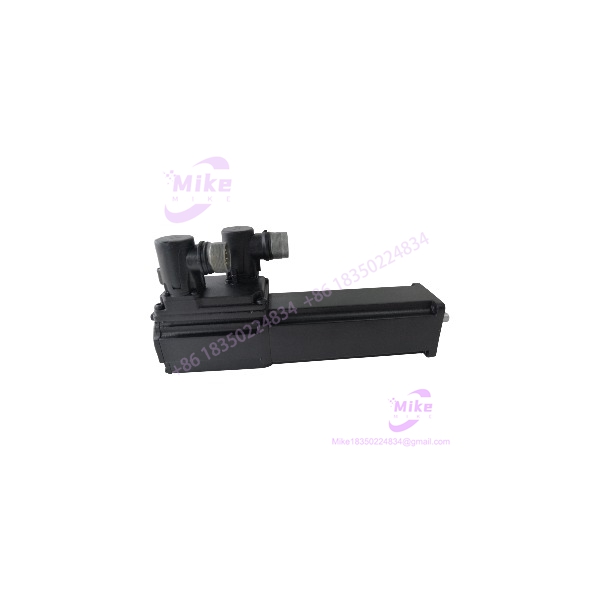
MKD025B-144-KG1-UN
Key Technical Specifications
- Manufacturer: Bosch Rexroth Indramat
- Series: MKD Synchronous Motors
- Exact Model: MKD025B-144-KG1-UN
- Material Number: R911288403
- Motor Type: Digital AC synchronous servo motor
- Motor Size: 025
- Motor Length: B
- Winding Code: 144
- Continuous Torque at Standstill: 0.9 Nm
- Maximum Speed: 6,000 RPM
- Resolver Feedback: Yes
- Integrated Encoder: Yes
- Position Detection: Absolute, greater than 4,096 revolutions
- Holding Brake: Yes
- Holding Brake Torque: 1 Nm
- Shaft Design: Plain/smooth shaft
- Shaft Seal: Yes
- Flange Size: 54 mm
- Centering Diameter: 40 mm
- Cooling: Natural convection
- Connection Direction: Adjustable through 270°
- Connection Type: Power and encoder connectors
- Insulation Class: F
- Weight: Approximately 1.5 kg
The 1 Nm brake rating is supported by the exact-model technical references. Some third-party pages incorrectly publish 22 Nm for this small MKD025 configuration; that value should not be used for procurement. The Rexroth type-code documentation also identifies KG1 as a resolver/multiturn configuration with a holding brake.
Application Scenarios & Pain Points
1. Compact Machine-Tool Axes
The MKD025B-144-KG1-UN can be used in compact servo axes where controlled speed and position are required without the physical envelope of a larger motor.
Engineering pain point: A 54 mm flange does not make every 025-frame MKD interchangeable. The winding, feedback, brake, and shaft configuration still have to match the original machine.
2. Packaging and Indexing Equipment
The integrated multiturn absolute feedback arrangement is relevant to positioning axes where the controller needs absolute position information over multiple motor revolutions.
Pain point: Resolver feedback should be verified against the connected drive’s supported feedback interface and parameter set before commissioning.
3. Small Material-Handling Axes
The 0.9 Nm continuous standstill torque provides a defined reference for compact positioning mechanisms.
Pain point: The 1 Nm holding brake is a mechanical holding device. It should not automatically be treated as the machine’s dynamic stopping system or as sufficient for every vertical-load condition.
4. Legacy Indramat Servo Systems
This exact motor is relevant when restoring older Rexroth/Indramat machinery while preserving the original mounting, feedback, brake, and motor parameter configuration.
Procurement pain point: Search by the complete MKD025B-144-KG1-UN / R911288403 identity. The MKD025B-144 family contains numerous GG, GP, KG, and KP configurations, with different feedback and brake combinations.
QA & Live Testing SOP
1. Identity Verification
Before accepting the motor:
- Photograph the complete nameplate.
- Confirm MKD025B-144-KG1-UN.
- Cross-check R911288403.
- Verify motor size 025.
- Verify length B.
- Verify winding code 144.
- Confirm KG1 configuration.
- Confirm the integrated holding brake is physically present.
- Record serial number and manufacturing information when available.
2. Mechanical Inspection
Inspect:
- 54 mm mounting flange.
- 40 mm centering pilot.
- Plain shaft.
- Shaft seal.
- Bearing condition.
- Motor housing.
- Power connector.
- Encoder connector.
- Brake assembly.
- Connector rotation mechanism.
Rotate the shaft manually and check for roughness, abnormal bearing noise, mechanical binding, or excessive radial/axial play.
3. Brake Test
Because the KG1 configuration includes a holding brake:
- Inspect brake wiring and connector condition.
- Verify brake coil resistance against the applicable Rexroth service specification.
- Use a controlled brake test supply.
- Confirm mechanical release.
- Remove brake power and verify engagement.
- Confirm that the brake does not drag when released.
- Record release and engagement behavior.
The exact configuration is documented with a 1 Nm holding brake.
4. Motor and Feedback Test
Use a compatible Rexroth drive/test system rather than applying uncontrolled voltage directly to the motor.
Verify:
- Phase-to-phase winding consistency.
- Insulation resistance using an appropriate motor test procedure.
- Resolver feedback recognition.
- Integrated absolute encoder recognition.
- Absolute multiturn position data.
- Encoder fault status.
- Controlled low-speed rotation.
- Correct direction.
- Current balance.
- Bearing noise.
- Abnormal vibration.
5. Controlled Functional Test
Where suitable test equipment is available, run the motor under a controlled load.
Record:
- Initial temperature.
- Motor current.
- Speed.
- Feedback status.
- Brake status.
- Drive alarms/faults.
- Position feedback stability.
- Vibration.
- Temperature rise.
The published maximum speed is 6,000 RPM, but a service test should not simply command maximum speed. Use the applicable Rexroth motor/drive parameters and controlled acceleration limits.
6. Packaging
- Protect the plain shaft from impact.
- Protect the encoder and power connectors.
- Prevent the motor from moving inside the carton.
- Use ESD-conscious handling around the feedback electronics.
- Protect the flange and centering surface.
- Prevent the shaft seal from being compressed or damaged during packing.
Field Engineer’s Pitfall Guide
❗ Do not confuse KG1 with GG1, GP1, or KP1. The MKD type code identifies different resolver/feedback and shaft configurations. The exact suffix must match the machine’s original motor.
❗ The correct brake rating is 1 Nm. Some third-party pages incorrectly list 22 Nm for this motor. That value is not consistent with the exact-model references and should not be copied into a purchase specification.
❗ Resolver plus integrated encoder is part of the configuration. Do not substitute an MKD025 motor with a different feedback system merely because its mechanical dimensions appear compatible.
❗ The shaft is plain. The G shaft designation in the Rexroth MKD type-code documentation corresponds to a smooth shaft, while K identifies a shaft with keyway. This model uses KG1, so the G position indicates the plain-shaft configuration.
❗ Do not confuse the 0.9 Nm continuous standstill torque with the 1 Nm brake torque. They describe different motor functions and should be treated separately in machine calculations.
❗ Verify the drive parameter set. The 144 winding code is part of the motor’s identity. Using parameters from another MKD025 motor can produce incorrect current limits, commutation, speed behavior, or drive faults.
Intent-Driven FAQ
Q: What is the exact Rexroth order number for ?
A: The material/order number is R911288403.
Q: What is the continuous standstill torque?
A: The exact configuration is specified at 0.9 Nm continuous torque at standstill.
Q: What is the maximum speed?
A: The exact-model technical reference specifies 6,000 RPM. Do not substitute the 9,000 RPM figure sometimes published for other variants.
es the have a holding brake?
A: Yes. The KG1 configuration has a 1 Nm holding brake.
Q: What feedback does this motor use?
A: It uses resolver feedback with an integrated multiturn absolute encoder, providing absolute position detection beyond 4,096 revolutions.
Q: What shaft configuration does it have?
A: It uses a plain/smooth shaft with a shaft sealing ring.
Q: What are the mounting dimensions?
A: The motor has a 54 mm flange and 40 mm centering diameter.
Q: Can I replace another motor with this unit?
A: Not automatically. Confirm the complete model code, winding 144, KG1 feedback configuration, brake, shaft design, connector arrangement, and Rexroth drive parameters before approving the substitution.
Q: What condition should be specified when sourcing this motor?
A: Unless inspection records are supplied, specify Legacy / Verify Condition and require nameplate verification, mechanical inspection, brake testing, resolver/encoder verification, and controlled motor testing before acceptance.