

Description
Bosch Rexroth MKD090B-047-KG1-KN | 4.8 kW Servo
Product Introduction
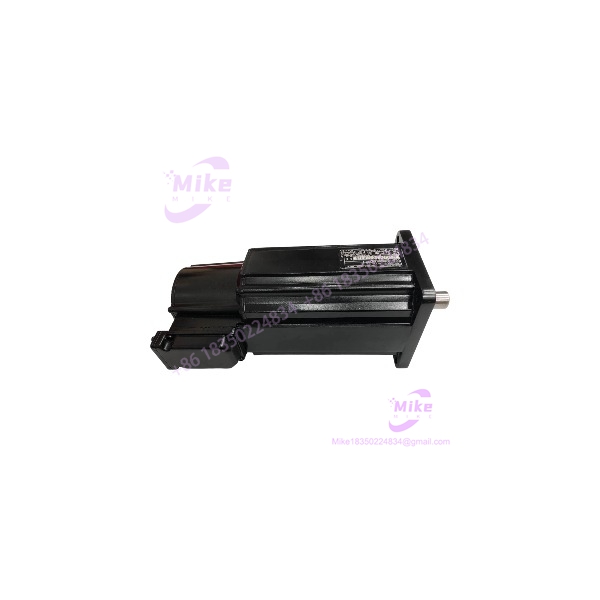
Built for legacy Indramat motion platforms, the Bosch Rexroth Indramat MKD090B-047-KG1-KN is a permanent-magnet synchronous servo motor in the MKD family. Its complete configuration combines the 090 frame, B-length housing, 047 winding, resolver feedback with integrated multiturn absolute encoder, plain sealed shaft, 11 Nm holding brake, and terminal-box connection.
The 047 winding provides a documented 3,500 RPM rated speed and 9.9 Nm rated torque at the 100 K natural-cooling operating point, with 4.8 kW rated output, 8.4 A rated current, 351 V rated voltage, and 59.4 A peak current. The motor also supports a documented 5,000 RPM maximum speed and 12.0 Nm continuous standstill torque under the 60 K natural-cooling condition.
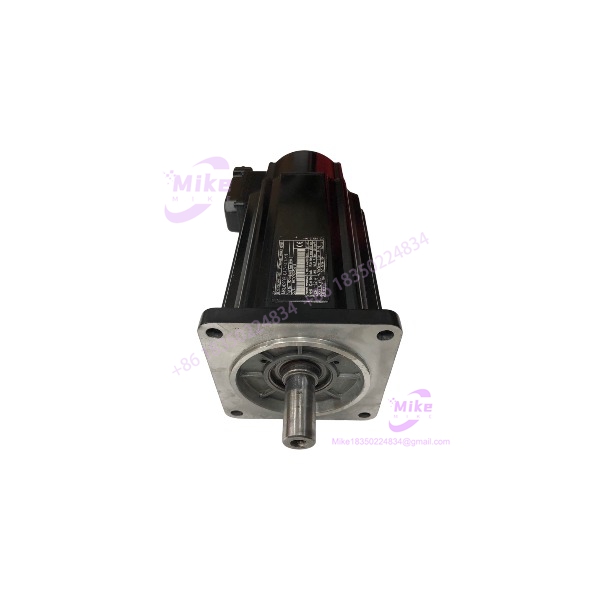
MKD090B-047-KG1-KN
Key Technical Specifications
- Manufacturer: Bosch Rexroth Indramat
- Model: MKD090B-047-KG1-KN
- Material Number: R911262939
- Motor Family: MKD synchronous motor
- Motor Size: 090
- Motor Length: B
- Winding Code: 047
- Feedback: Resolver with integrated multiturn absolute encoder
- Position Detection: Absolute, greater than 4,096 revolutions
- Shaft: Plain shaft with shaft sealing ring
- Holding Brake: Integrated
- Brake Torque: 11 Nm
- Brake Voltage: 24 VDC
- Brake Current: Approximately 0.71 A
- Rated Speed: 3,500 RPM
- Characteristic Motor Speed: 3,200 RPM
- Maximum Speed: 5,000 RPM
- Rated Torque: 9.9 Nm at 100 K natural cooling
- Continuous Standstill Torque: 12.0 Nm at 60 K natural cooling
- Theoretical Maximum Torque: 43.5 Nm
- Rated Current: 8.4 A at the 100 K rating point
- Continuous Standstill Current: 13.3 A at 60 K natural cooling
- Peak Current: 59.4 A
- Rated Voltage: 351 V at the 100 K rating point
- Rated Output: 4.8 kW at the 100 K rating point
- Rated Frequency: 233 Hz
- Torque Constant: Approximately 1.05 Nm/A at 20°C
- Voltage Constant: 91 V/1,000 RPM at 20°C
- Winding Resistance: 1.2 ohms at 20°C
- Winding Inductance: 10.1 mH
- Pole Pairs: 4
- Rotor Inertia: 43.0 × 10⁻⁴ kg·m²
- Flange Size: 140 mm
- Centering Diameter: 110 mm
- Protection: IP65
- Insulation Class: F
- Cooling: Natural convection
- Connection: Terminal box, Side B
- Motor Mass: Approximately 14 kg
- Ambient Temperature: 0 to +40°C
- Condition: Legacy / verify condition
Application Scenarios & Pain Points
CNC and Machine-Tool Servo Axes
The MKD090B-047-KG1-KN is suited to legacy Rexroth motion systems where resolver feedback, the 047 winding, and the mechanical mounting configuration match the original motor.
Pain point: A physically compatible motor can still generate feedback or parameter errors if the resolver/encoder configuration does not match the existing drive setup.
Vertical or Gravity-Loaded Axes
The integrated 11 Nm holding brake provides a mechanical holding function when the servo torque is removed.
Pain point: Brake torque must not be confused with motor rated torque. The brake is a holding device, not a substitute for continuous servo torque during motion.
Packaging and Indexing Machinery
The combination of 3,500 RPM rated speed, 9.9 Nm rated torque at the applicable 100 K point, and absolute multiturn feedback supports applications requiring repeatable rotary positioning.
Pain point: The brake-release sequence must be coordinated with servo enable. An unreleased brake can cause current buildup, poor acceleration, following errors, and motor heating.
Legacy Servo Motor Replacement
The exact MKD090B-047-KG1-KN configuration is useful when maintaining an existing MKD installation without changing the motor’s frame and feedback architecture.
Pain point: The G shaft designation means plain shaft, so a replacement specified with a keyed P shaft is not automatically a mechanical equivalent.
QA & Live Testing SOP
- OEM Identity Verification
- Confirm the physical nameplate reads MKD090B-047-KG1-KN.
- Verify material/order number R911262939 where available.
- Record serial number, production information, and nameplate markings.
- Compare the complete type code rather than relying only on the MKD090B-047 base designation.
- Mechanical Inspection
- Inspect the 140 mm flange and 110 mm centering interface.
- Confirm the shaft is plain, not keyed.
- Inspect the shaft sealing ring for cracking, deformation, or leakage.
- Check bearings for abnormal radial or axial play.
- Release the brake using the correct procedure before evaluating free shaft rotation.
- Brake Test
- Verify the brake circuit is designed for approximately 24 VDC.
- Check brake resistance and electrical continuity.
- Apply controlled brake-release voltage using appropriate test equipment.
- Confirm the shaft releases cleanly without excessive drag.
- Remove release power and verify the brake re-engages correctly.
- Feedback Test
- Verify the resolver and integrated multiturn absolute encoder.
- Inspect feedback wiring, shielding, terminals, and connector condition.
- Test feedback with a compatible Rexroth drive or approved diagnostic equipment.
- Confirm position feedback remains stable through controlled shaft rotation.
- Winding Test
- Measure phase-to-phase resistance at a recorded winding temperature.
- Compare the three phases for reasonable symmetry.
- Perform an appropriate insulation-resistance test before energizing.
- Investigate abnormal phase imbalance before connecting the motor to a servo amplifier.
- Controlled Live Test
- Use a compatible Rexroth drive with verified motor parameters.
- Confirm brake-release sequencing before commanding motion.
- Start at low speed and low mechanical load.
- Verify resolver/absolute position feedback, direction, current, and following error.
- Monitor motor temperature and vibration during the test.
- Increase speed and load progressively only after the initial test passes.
- ESD-Safe Packaging
- Protect feedback electronics from ESD exposure.
- Protect the plain shaft and sealing ring from impact.
- Keep the terminal box protected from conductive debris and moisture.
- Secure the approximately 14 kg motor against movement during shipment.
Field Engineer’s Pitfall Guide
❗ Do not confuse KG1 with GP1 or KP1.
The KG1 configuration uses resolver feedback with integrated multiturn absolute encoder, a plain shaft, and a holding brake. GP1 uses a keyed shaft configuration, while KP1 combines the K feedback configuration with a keyed shaft. Verify the complete type code before ordering a replacement.
❗ The holding brake is 11 Nm, not 22 Nm.
Some secondary listings incorrectly show higher brake-torque values for this model. The Rexroth MKD documentation and multiple exact-model references identify the KG1 configuration with an 11 Nm holding brake.
❗ Do not energize the motor against a locked brake.
The servo drive can generate substantial current while the mechanical shaft remains stationary if the brake does not release. Check 24 VDC brake operation and actual mechanical release before applying motion commands.
❗ Verify the feedback architecture.
The K feedback designation is materially different from the G resolver-only configuration. Do not copy parameters from an MKD090B-047-GG1-KN or GG0-KN installation without verifying the actual feedback hardware.
❗ Rated torque depends on the cooling/rating point.
The 047 winding has multiple documented operating points. The commonly quoted 9.9 Nm / 4.8 kW / 8.4 A / 351 V values correspond to the 100 K natural-cooling rating point; the lower 60 K natural-cooling point is documented separately.
❗ Peak current is not continuous current.
The winding documentation specifies 59.4 A peak current, while the continuous standstill current is much lower. Drive current limits must be matched to the motor and application profile rather than using the peak value as a continuous operating target.
Intent-Driven FAQ
Q: What is the exact part number for this servo motor?
A: The exact model is , with material/order number R911262939.
Q: What es the use?
A: It uses resolver feedback with an integrated multiturn absolute encoder. The K feedback designation distinguishes it from the resolver-only G configuration.
es the have a brake?
A: Yes. KG1 specifies a holding-brake configuration. The documented brake torque is 11 Nm, with 24 VDC supply and approximately 0.71 A brake current.
Q: Is the shaft keyed?
A: No. The G shaft designation specifies a smooth/plain shaft with a shaft sealing ring. A keyed shaft belongs to the K shaft designation.
Q: What are the primary motor ratings?
A: For the documented 100 K natural-cooling rating point, the winding is rated at 4.8 kW, 3,500 RPM, 9.9 Nm, 8.4 A, 351 V, and 233 Hz.
Q: What is the maximum speed?
A: The documented maximum speed for the winding is 5,000 RPM.
Q: What is the continuous standstill torque?
A: The documented value is 12.0 Nm at 60 K natural cooling, increasing to 15.0 Nm at the documented 60 K surface-cooling point.
Q: Is interchangMKD090B-047-GG1-KN?
A: They share the 047 winding and basic MKD090B motor platform, but the feedback configuration differs: KG1 uses the K feedback configuration with integrated multiturn absolute encoder, while GG1 uses G resolver feedback. The complete machine-drive interface must be verified before substitution.
Q: What should be checked before inlegacy ?
A: Verify the complete type code, R911262939 material number, resolver/encoder compatibility, plain-shaft coupling, 11 Nm brake operation, brake-release sequencing, winding condition, insulation resistance, connection-box wiring, and compatible Rexroth drive parameters.





