
Description
Kollmorgen AKM42E-EKGNR-01 | Synchronous Servo Motor Core Category
Dynamic Product Introduction
Scaling up torque output without sacrificing dynamic loop response requires a larger magnetic footprint. The Kollmorgen AKM42E-EKGNR-01 combines a robust 84mm frame profile with an optimized core stack, delivering dependable high-torque performance for automated machine tools and material handling gantries. Sourcing this exact high-resolution feedback configuration ensures drop-in compatibility with legacy drive loops, eliminating the need for expensive software retrofits.
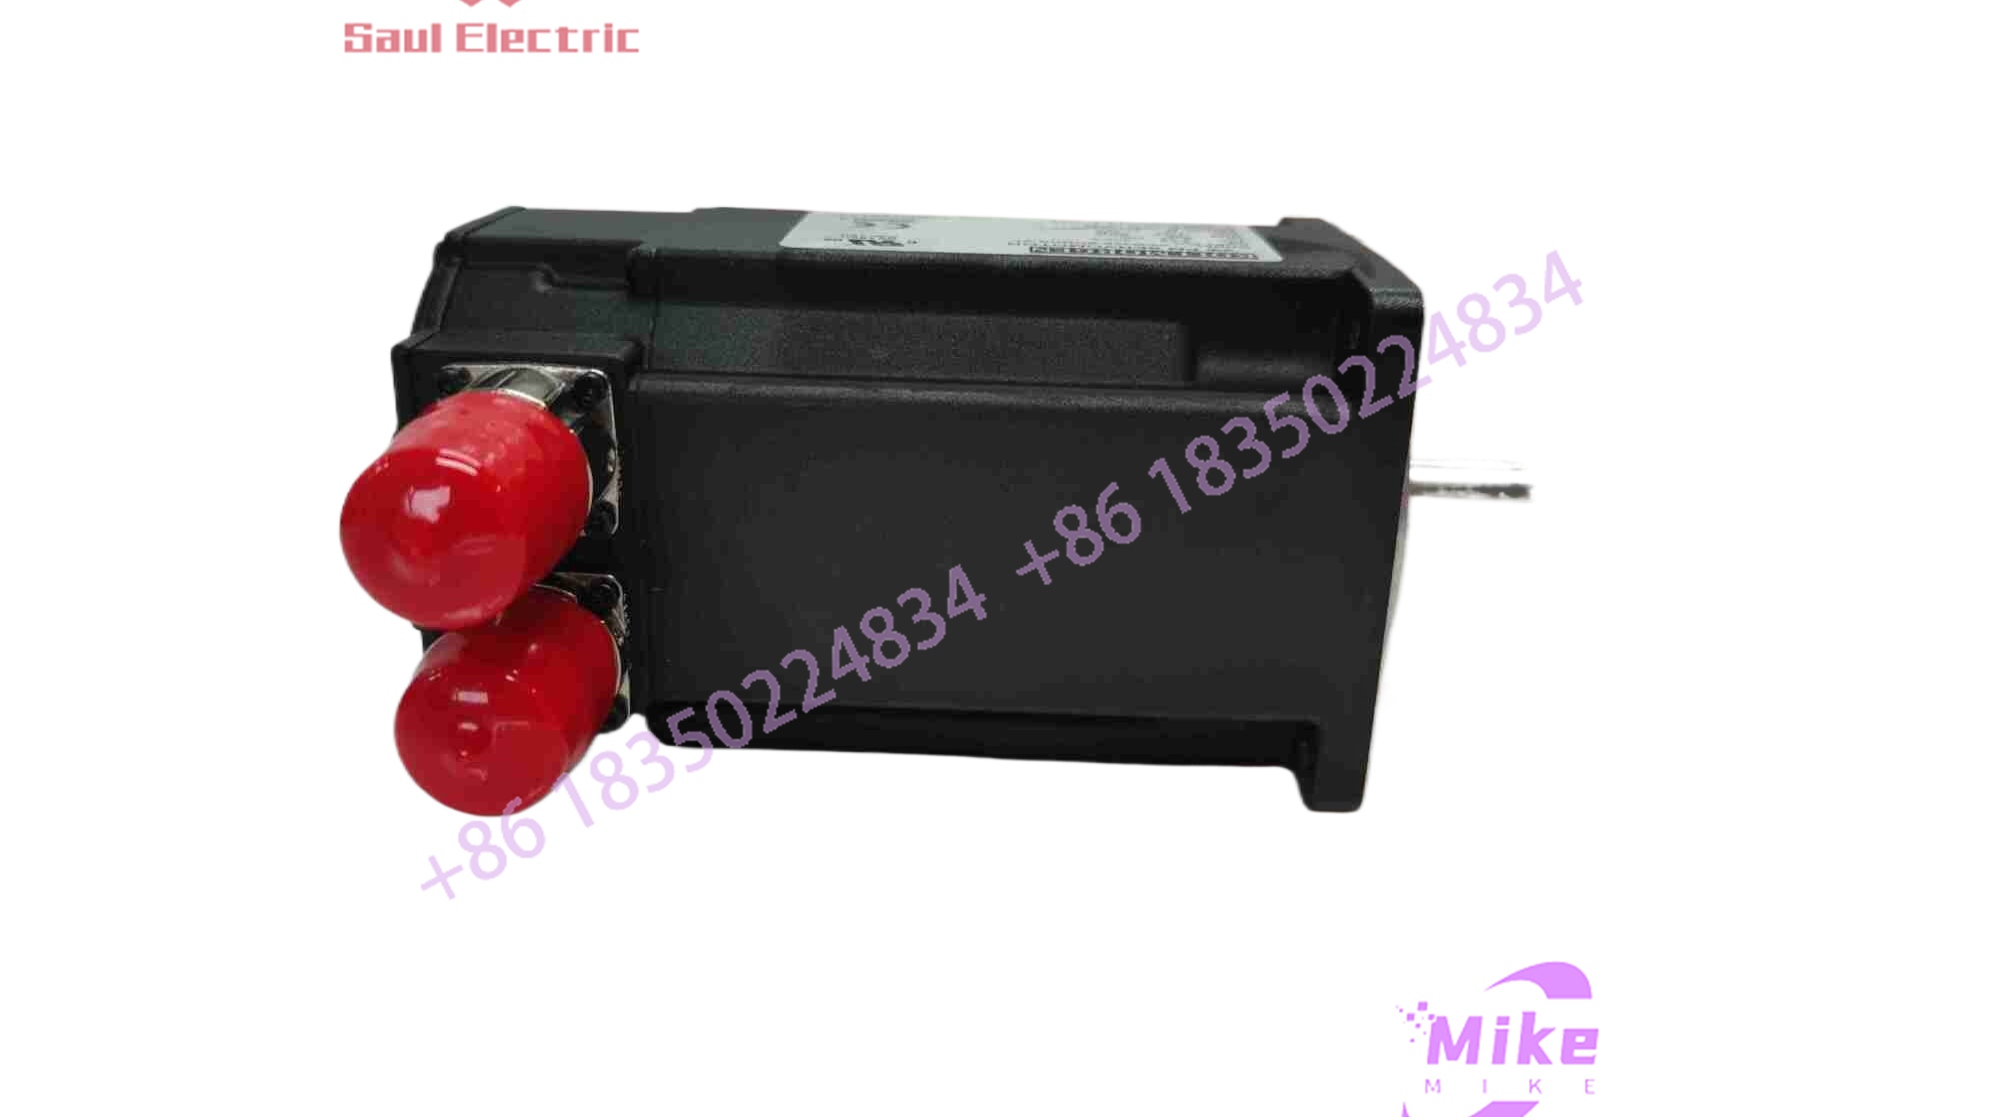
AKM42E-EKGNR-01
Key Technical Specifications
| Technical Parameter | Specification Value |
| Flange Size | 84 mm (Frame 4, IEC metric mounting) |
| Stack Length | 2 (Standard medium core variant) |
| Winding Type | E (Optimized high-voltage winding) |
| Feedback Device | EnDat absolute digital feedback (-01 / EKG variant) |
| Holding Brake | None (-N suffix) |
| Rated Output Power | 1.48 kW / 1.98 HP (at 640 VDC bus) |
| Stall Torque | 4.83 Nm (42.7 lb-in) |
| Max Bus Voltage | 640 VDC |
| Rated Speed | 4000 RPM (7000 RPM max operating limit) |
| Enclosure Rating | IP65 (Dust-tight and protected against water jets) |
Global Sourcing & Live-Test SOP (Transparency Core)
Validating surplus or replacement high-output servo motors demands rigorous electrical and mechanical screening before deployment. Every inbound AKM42E-EKGNR-01 unit is processed through a strict protocol:
- Inbound Verification: Serial number pedigree checks against OEM factory databases, laser nameplate validation, and physical shaft runout verification using high-precision dial indicators.
- Live Simulation: Mounted securely to a calibrated dynamometer test rig driven by an authentic digital servo controller.
- Diagnostics: 1000VDC megger insulation resistance testing, phase-to-phase back-EMF symmetry verification, and digital EnDat communication packet validation across full thermal cycling.
- Final Prep: Protective plastic shaft capping, moisture barrier insertion, and heavy-duty ESD-safe vacuum sealing.
The Field Engineer’s Pitfall Guide
- ❗ EnDat Communication Packet Loss: Running the multi-wire digital feedback cable alongside noisy high-frequency VFD output lines without proper 360-degree shield termination will corrupt absolute position packets, throwing drive fault warnings.
- ❗ Shaft Coupling Side-Loading: Hanging heavy timing pulleys directly onto the standard shaft without an outboard support bearing will deflect the rotor and cause premature front-bearing fatigue.
- ❗ Thermal Overload via Continuous Stall: Ignoring the continuous stall current rating when holding heavy loads statically without external cooling will trip the internal PTC thermistor and drop the axis.
Intent-Driven FAQ
- Does the AKM42E-EKGNR-01 require an internal battery for its EnDat feedback?
EnDat absolute feedback variants may require a backup battery on the multi-turn absolute counter depending on the specific multi-turn encoder generation, though single-turn versions operate without battery reliance.
- Can this motor be hot-swapped while the drive bus is energized?
Never unplug power or feedback connectors while the DC bus is active. Always lock out upstream power and wait for the bus capacitors to bleed down to prevent arcing damage to the M23 pin contacts.
- What indicates an internal winding failure during routine maintenance?
Measuring phase-to-phase resistance with a milliohmmeter and discovering an asymmetry exceeding three percent typically points toward localized turn-to-turn short circuits.
- Are mating power and feedback cables included with surplus units?
Surplus motors ship with integrated housing receptacles; matching shielded cable assemblies must be specified and ordered separately based on your cable tray run length.
- What warranty protects this surplus hardware?
Verified units are backed by an industry-standard replacement warranty covering electrical and mechanical integrity under specified operational loads.