

Description
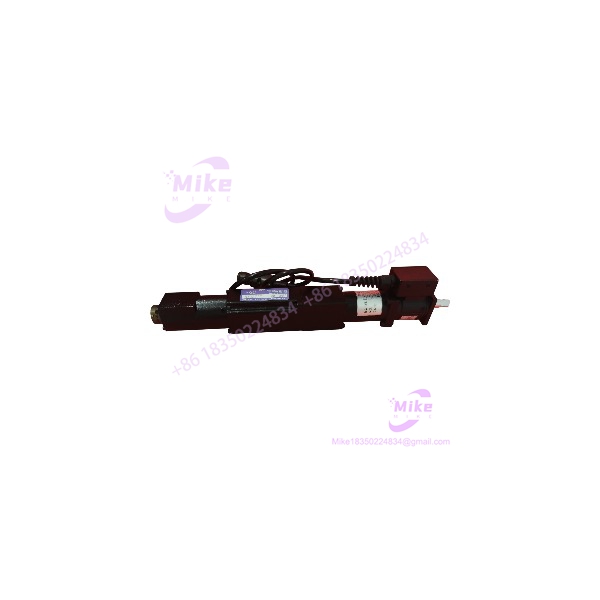
FEC NFT401RM1A-S | DC Servo Nutrunner Spindle Unit
Dynamic Product Introduction
Assembly cell downtime caused by erratic tightening cycles usually forces maintenance teams to swap out hardware immediately. When a high-torque electric spindle starts throwing over-current faults or fails to meet target angle thresholds, the FEC NFT401RM1A-S serves as the exact direct-fit replacement needed to restore line production without software rewrites.
The FEC NFT401RM1A-S operates as an intelligent closed-loop fastening spindle, communicating real-time torque and rotational position data back to the multi-axis system controller. Built for high-volume powertrain and chassis assembly, it ensures repeatable clamp load generation across thousands of daily rundown cycles.
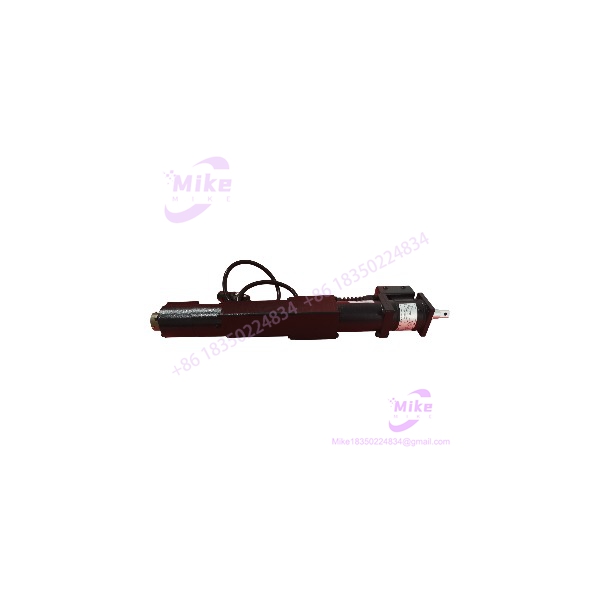
NFT401RM1A-S
Key Technical Specifications
- Model Number: FEC NFT401RM1A-S
- Manufacturer: FEC / Daiichi Dentsu
- Tool Classification: Inline DC Servo Nutrunner
- Maximum Torque: 39.2 Nm
- Rated Speed: 250 rpm
- Feedback Device: High-resolution resolver
- Operating Voltage: Servo amplifier DC bus driven
- Operating Temperature: 0°C to +40°C (32°F to 104°F)
- Mounting Style: Flange bracket fixture mount
- Cooling Interface: Natural convection housing
Global Sourcing & Live-Test SOP (Transparency Core)
Acquiring surplus or replacement fastening spindles requires strict verification protocols to guarantee mechanical integrity before installation.
1.Inbound Visual & Serial Verification:Prerequisite。
Inspect the outer casing for impact damage, verify serial tags against OEM manufacturing records, and check output drive shaft play.
2.Static Winding & Insulation Check:5 min。
Measure motor phase-to-phase resistance and insulation breakdown voltage on the power leads using a digital multimeter and insulation tester.
3.Dynamic Test Bench Run:20 min。
Mount the FEC NFT401RM1A-S to a calibrated multi-axis test controller. Execute simulated rundown profiles against a dynamic torque simulator to verify angle and torque tracking accuracy.
4.Thermal Soak & ESD Sealing:24 Hours。
Cycle the spindle through repetitive high-load rundowns in a thermal chamber for 24 hours. Seal the unit in an anti-static bag with desiccant upon passing.
The Field Engineer’s Pitfall Guide
Critical Installation Warnings
Verify motor phase mapping, resolver zero offsets, and mechanical alignment before energizing replacement servo spindles.
❗ 1. Mismatched Resolver Phasing During Cable Replacement
—When installing a replacement FEC NFT401RM1A-S, plugging the feedback cable into an incorrect port or mismatching phase lines can cause violent motor oscillation or immediate thermal foldback upon controller startup. Always verify cable tags against the system port map.
❗ 2. Imposing Lateral Side-Loads on the Spindle Shaft
I’ve seen assembly plants destroy brand-new fastening spindles within weeks because the mounting fixture exerted a slight side-load on the drive output. Nutrunner spindles are engineered strictly for axial torque delivery; any mechanical binding ruins the internal bearings.
❗ 3. Hot-Plugging Motor Power Connectors
Disconnecting or connecting the high-voltage motor power plug while the controller amplifier is energized will pit connector pins and can damage the drive output transistors. Always isolate controller power before servicing tool cabling.
Intent-Driven FAQ
Will swapping out the FEC NFT401RM1A-S require recalibrating torque limits in the controller?
Usually, no. Torque scaling parameters and calibration coefficients are stored in the system controller configuration file. However, verifying joint torque output with an external rotary sensor after installation is best practice.
What causes an amplifier over-current fault during a rundown?
An over-current trip typically indicates mechanical binding in the threaded joint, a failing internal gearbox, or a damaged motor power cable running from the control cabinet.
Can this servo spindle be repaired on-site if the internal planetary gearbox fails?
Precision fastening spindles require clean-room conditions and specialized alignment jigs to rebuild internal gear trains and resolvers. Field repairs are strictly limited to cable replacement and external mounting adjustments.
How do I confirm that the controller recognizes the replacement tool?
Check the diagnostic display on your system controller interface. A ready status indicator confirms that internal safety loops and resolver feedback channels are communicating correctly.
What warranty coverage applies to replacement servo spindles?
Standard procurement warranties cover mechanical integrity, motor windings, and internal sensor functionality for 12 months from the date of purchase.





